eventSeminar
HAI Weekly Seminar with Dorsa Sadigh
Walking the Boundary of Learning and Interaction
Get the latest news, advances in research, policy work, and education program updates from HAI in your inbox weekly.
Sign Up For Latest News
Walking the Boundary of Learning and Interaction
An AI Measurement Science (AIMS) Seminar Series
An AI Measurement Science (AIMS) Seminar Series
Phil Lewis from the National Center for O*NET Development will talk about data infrastructure the US Department of Labor provides, and how AI is used to update it. A panel with Diyi Yang from the Stanford Computer Science Department and DEL’s Erik Brynjolfsson will discuss the opportunities of a new partnership between Stanford and the National Center for O*NET Development.
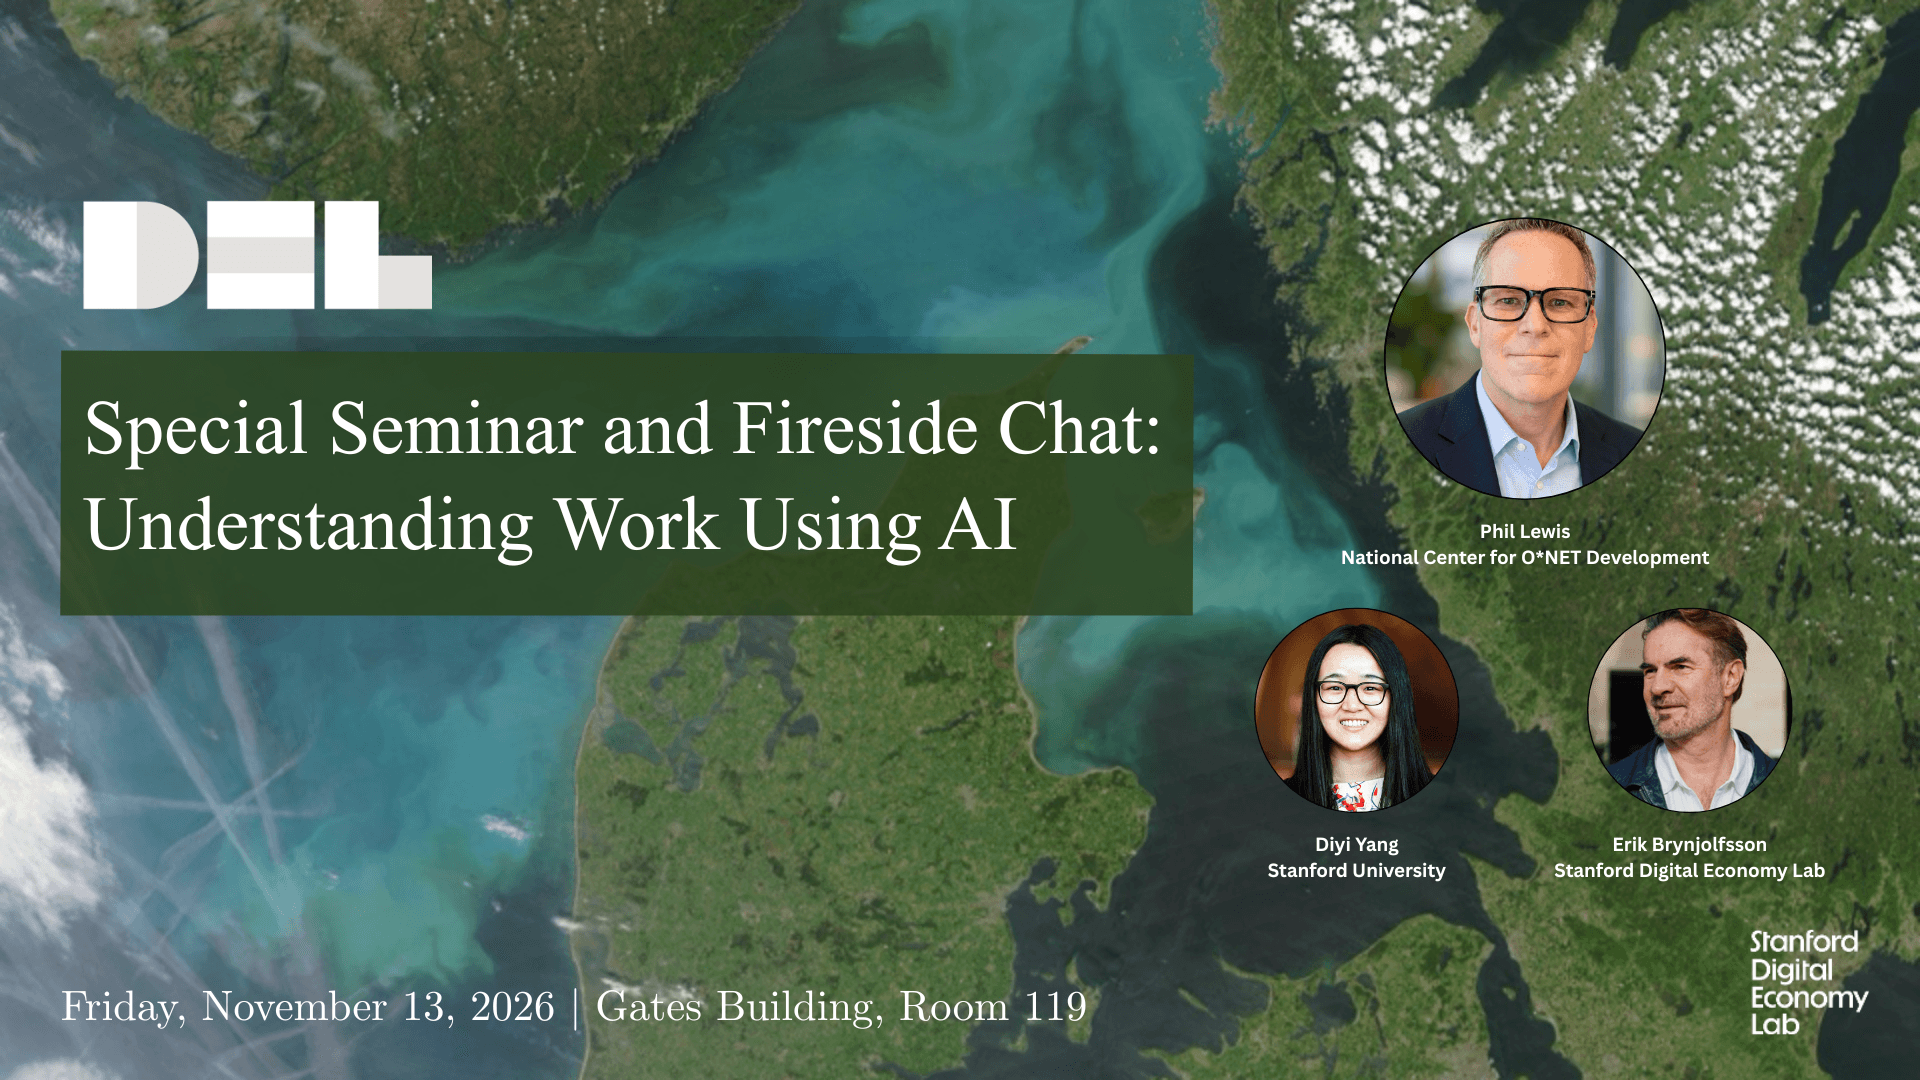
Phil Lewis from the National Center for O*NET Development will talk about data infrastructure the US Department of Labor provides, and how AI is used to update it. A panel with Diyi Yang from the Stanford Computer Science Department and DEL’s Erik Brynjolfsson will discuss the opportunities of a new partnership between Stanford and the National Center for O*NET Development.
In the last year, AI models have rapidly improved on public benchmarks measuring their ability to carry out research tasks autonomously. Such performance suggests that models may be capable of automating parts of the AI R&D process itself, thereby accelerating the pace of AI progress.
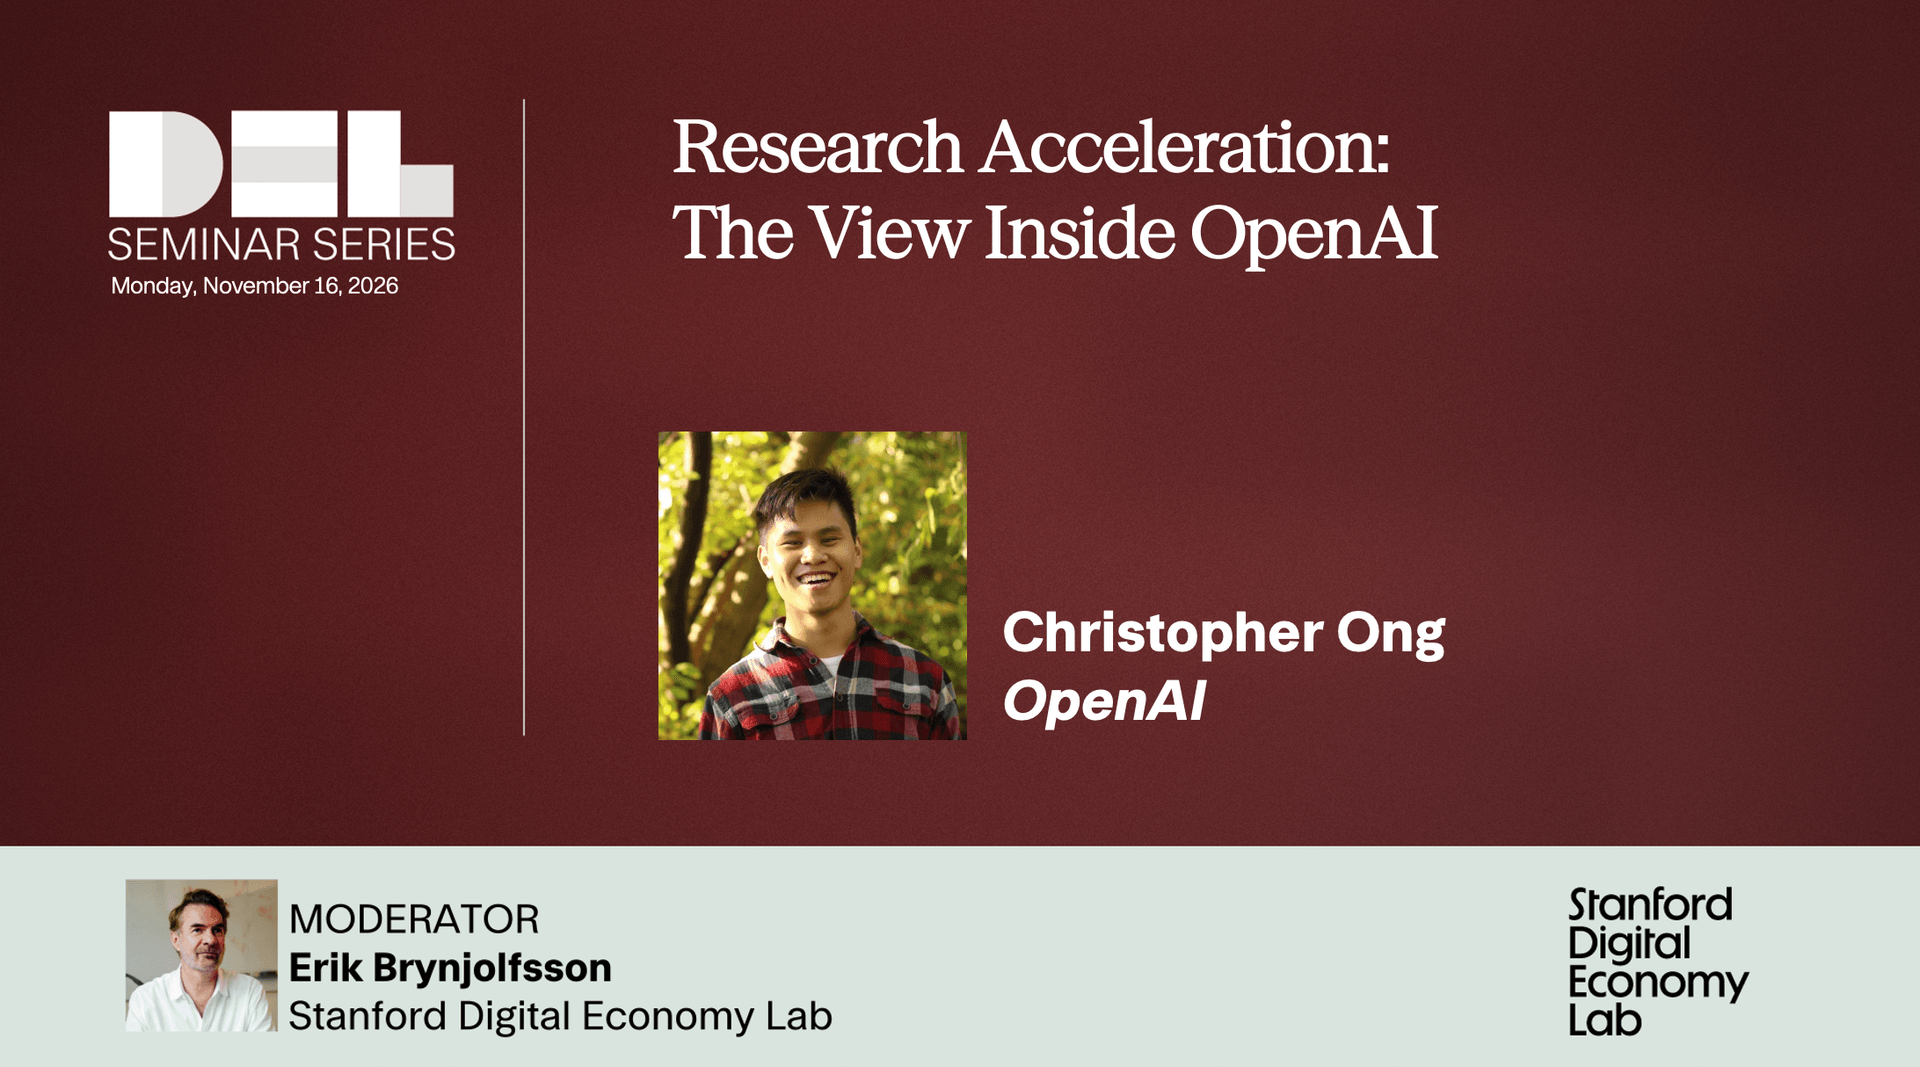
In the last year, AI models have rapidly improved on public benchmarks measuring their ability to carry out research tasks autonomously. Such performance suggests that models may be capable of automating parts of the AI R&D process itself, thereby accelerating the pace of AI progress.
There have been significant advances in the field of robot learning in the past decade. However, many challenges still remain when considering how robot learning can advance interactive agents such as robots that collaborate with humans. This includes autonomous vehicles that interact with human-driven vehicles or pedestrians, service robots collaborating with their users at homes over short or long periods of time, or assistive robots helping patients with disabilities. This introduces an opportunity for developing new robot learning algorithms that can help advance interactive autonomy.
In this talk, I will discuss a formalism for human-robot interaction built upon ideas from representation learning. Specifically, I will first discuss the notion of latent strategies — low dimensional representations sufficient for capturing non-stationary interactions. I will then talk about the challenges of learning such representations when interacting with humans, and how we can develop data-efficient techniques that enable actively learning computational models of human behavior from demonstrations, preferences, or physical corrections. Finally, I will introduce an intuitive controlling paradigm that enables seamless collaboration based on learned representations, and further discuss how that can be used for influencing humans.
